Aalto Robot Learning
Aalto Robot Learning
Home
Team
Equipment
Publications
Opportunities
Light
Dark
Automatic
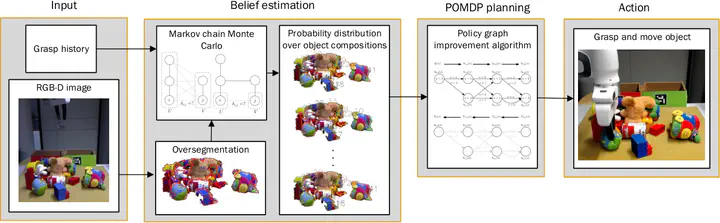
POMDP planning under object composition uncertainty: Application to robotic manipulation
Joni Pajarinen
,
Jens Lundell
,
Ville Kyrki
July 2022
PDF
Cite
Overview
Type
2
Publication
IEEE Transactions on Robotics
Source Themes
Cite
×