Aalto Robot Learning
Aalto Robot Learning
Home
Team
Equipment
Publications
Opportunities
Light
Dark
Automatic
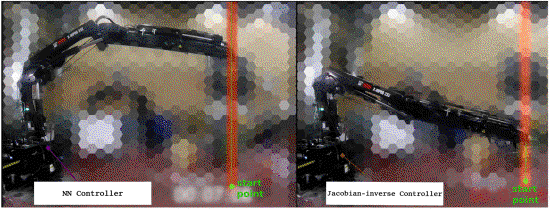
End-Effector Cartesian Velocity Control for Redundant Loader Cranes Using Reinforcement learning
Abdolreza Taheri
,
Amy Rankka
,
Pelle Gustafsson
,
Joni Pajarinen
,
Reza Ghabcheloo
November 2024
PDF
Cite
Video
Performance
Type
2
Publication
IEEE Transactions on Robotics
Source Themes
Cite
×