Aalto Robot Learning
Aalto Robot Learning
Home
Team
Equipment
Publications
Opportunities
Light
Dark
Automatic
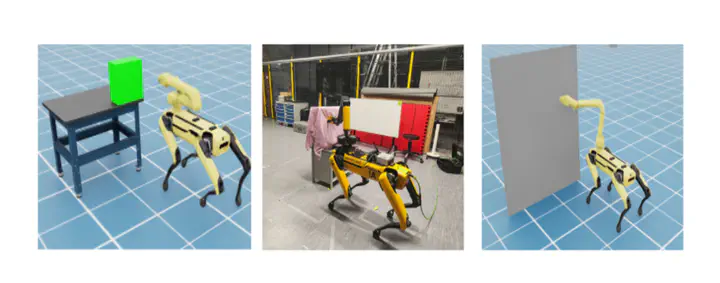
Manipulate-to-Navigate: Reinforcement Learning with Visual Affordances and Manipulability Priors
Yuying Zhang
,
Joni Pajarinen
August 2025
PDF
Cite
Image credit:
Unsplash
Type
1
Publication
IEEE/RSJ International Conference on Intelligent Robots and Systems
Source Themes
Cite
×