Aalto Robot Learning
Aalto Robot Learning
Home
Team
Equipment
Publications
Opportunities
Light
Dark
Automatic
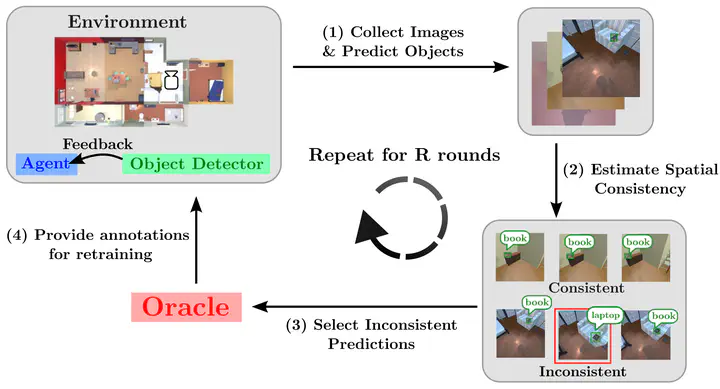
Embodied Active Learning under Limited Annotation and Navigation Budget for Object Detection
Hadrien Crassous
,
Mohamed Yassine Kabouri
,
Minahil Raza
,
Joni Pajarinen
,
Riad Akrour
June 2026
PDF
Cite
Code
Video
Website
Method Overview
Type
1
Publication
IEEE/RSJ International Conference on Intelligent Robots and Systems
Source Themes
Cite
×